 Robofauna
Walk
One policy handles forward, backward and turning on joystick commands. In simulation it walks forward at 0.14–0.17 m/s.
Walking in simRobofauna builds open-source physical AI robots. Train a policy with reinforcement learning in simulation, run it on a real NanoEmu, and follow the arm as it grows toward a humanoid. CAD, firmware, BOM and training code are all public.
A 25 cm biped on 14 bus servos. Its walking policy is trained with reinforcement learning in simulation, built to run on the robot itself.
Meet NanoEmu 02 · LearningReinforcement learning in the browser. MuJoCo physics and PPO run on your own GPU, with nothing to install.
See RL Lab 03 · ManipulationA human-scale robot arm with an adult's 700 mm reach and a 4 kg hold, for about the price of a laptop.
See the armNanoEmu is a 25 cm, 14-servo biped with reverse-knee legs and a beak that opens and closes. Its walking policy is trained with PPO reinforcement learning in MuJoCo, then made to run on the robot's own ESP32-S3 at 50 Hz with IMU feedback. Closing that simulation-to-real gap is what we are building, and the CAD, firmware and training code are all open.
 ≈ 250 mm
Concept render · final shell in CAD
PPO reinforcement learning in MuJoCo, thousands of robots at once in RL Lab.
Walking in simThe trained policy runs on NanoEmu's own ESP32-S3 at 50 Hz, steered by IMU feedback.
Sim-to-real in progressThe Base adds slow, on-device learning of behaviour once the robot is home.
ConceptRounded shells, few parts and exposed joints, all sized for a hobby 3D printer.
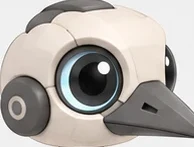
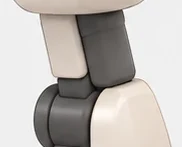
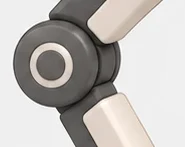
We mark each skill by where it actually stands. Walking comes from a PPO policy trained in MuJoCo, and the rest are on the way.
One policy handles forward, backward and turning on joystick commands. In simulation it walks forward at 0.14–0.17 m/s.
Walking in simHolds its stance after a 5 cm drop or a push, instead of just standing still in a calm pose.
In trainingBends down and grabs a sock off the floor with its beak. The pose reaches the ground in simulation.
In developmentRighting itself after a fall needs more torque and joint range than today's servos give. We are working on it in the open.
ResearchNanoEmu can't talk. It only acts. Add a NanoEmu Base, a small AI computer that lives next to it, and it starts growing the way an animal does: call its name often enough and one day it answers to it.
Concept stage · specs, price and date not set
Every part is off the shelf or 3D-printed. Buy the kit to skip the sourcing, or order parts one by one from the shop and print the shell yourself.
Servos are about 69% of the parts cost. We publish the BOM so you can check our price, or skip the kit and build from scratch.
Buying every part at retail today for a single robot costs about this much. The kit price is close to it, and every design file is free.
RL Lab trains walking and balance policies on your own CPU or GPU, with nothing to install and no cloud. Each robot gets its own experiment, with one policy per goal: stand without falling, or walk on command.
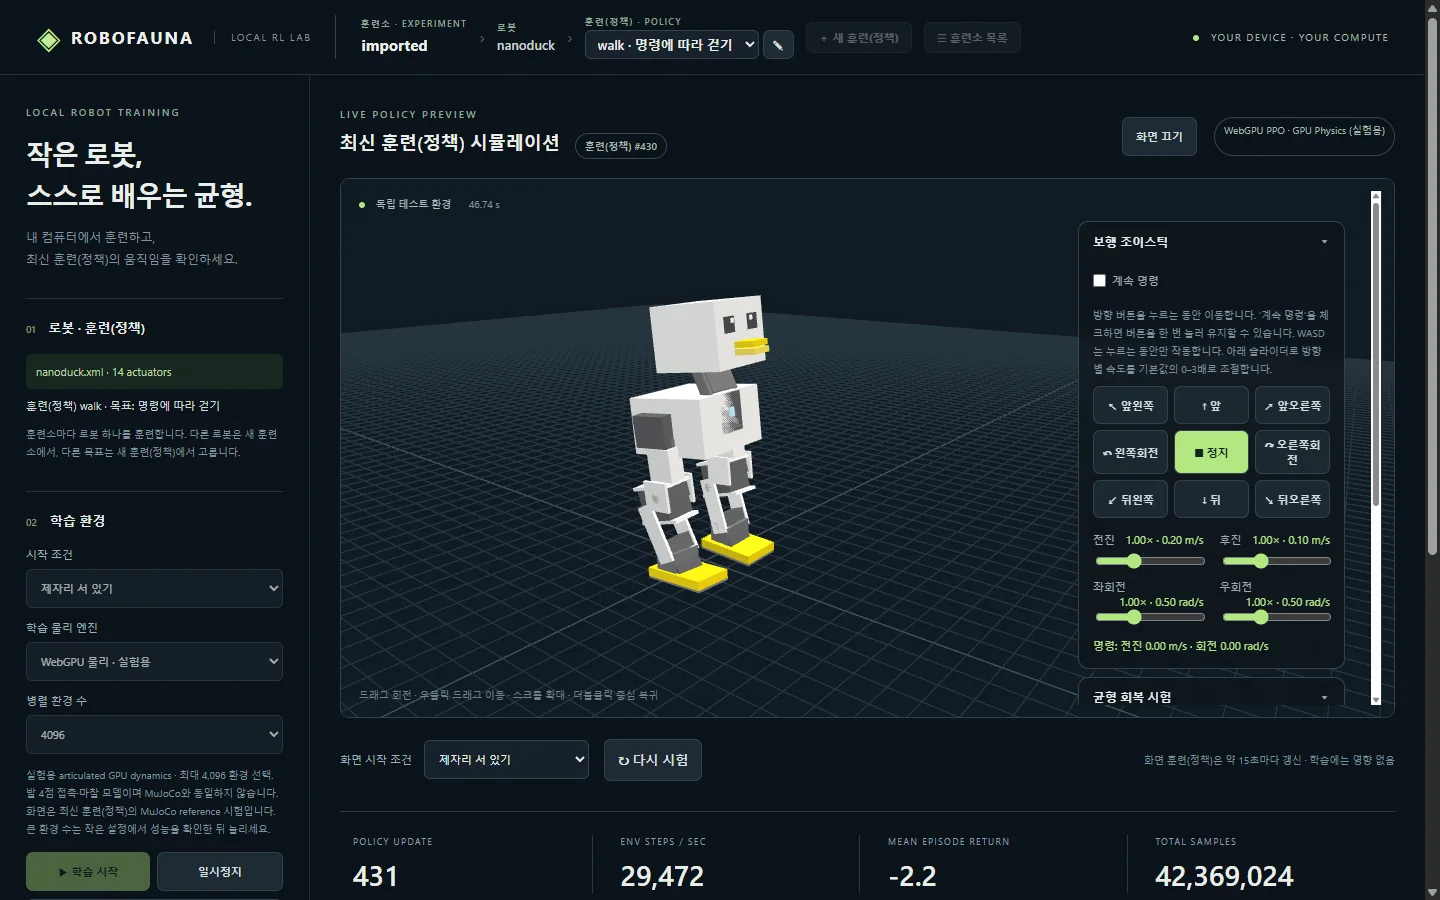
Development build screens · rl.robofauna.com
Walking on command works and passes an independent MuJoCo check. Sit and stand are next.
The same policies run on a real NanoEmu.
Import your own MuJoCo XML, from a robot dog to a hexapod or humanoid, and design rewards by hand or by chatting with AI.
Upload, download and remix robots and policies with the community.
Fixed-base reaching and tracking tasks.
From shoulder to fingertip Fauna Arm V1 spans about 700 mm, close to the arm of a 175 cm adult. It holds 4 kg fully extended. It is open hardware, and the full kit is $1,290.
 Concept render


Models, training code, design notes and the reasons behind each decision. Fork them, print them, improve them.
Each robot reuses the servos, boards and training stack of the last, so every project makes the next one cheaper.
GPU training walks in simulation. Next: firmware on the ESP32 and the first steps on real hardware.
Final shell CAD, leg PCB and BOM locked, then pre-orders are fulfilled.
A human-scale robot arm kit.
A small AI computer that lets NanoEmu grow habits of its own, learning a little every night while it charges.
Bring your own robot model, design rewards in plain language, and share policies.
Joints, boards and gearboxes from every earlier robot come together.
Your choice. The kit ($299) is DIY: you assemble the legs, head and body, wire the servo bus and flash the ESP32, with a guide published alongside the CAD. The assembled version ($369) arrives built, with all 14 servos calibrated, firmware installed and joints checked.
NanoEmu's movement is not scripted. It is a policy learned with reinforcement learning in a physics simulator, then run on a real body with servos and an IMU. Bridging the difference between simulation and the real robot (sim-to-real) is the core of the project. Everything is open, so you can retrain and change it yourself.
Not if you buy the printed shell set in the shop. If you have a printer, print the shell yourself in PLA or PETG (about 180 g) and buy only the parts you need.
It walks in simulation today with a PPO policy trained in MuJoCo, forward, backward and turning. Running that policy on the real robot (sim-to-real) is the current step. We will post progress openly.
RL Lab runs in a browser and uses whatever GPU you have through WebGPU. More GPU means more parallel robots and faster training, but no cloud and no install are needed.
CAD, firmware, BOM and training code are published on GitHub. The license for each repository will be listed there before the kits ship.
A separate, coming-soon add-on: a small AI computer that sits next to NanoEmu, watches and listens through its camera and microphone, and learns a little every night while the robot charges. NanoEmu stays a robot that acts rather than speaks, and it grows its own habits, including responding to its name. Everything stays on the Base and it works without internet. The plan is to turn what it sees and hears into compact learning data, delete the original video and audio right away, and delete that data once it has learned from it. Walking and movement policies keep running on NanoEmu's own ESP32. It is still at the concept stage, so details may change.
We will announce a shipping window once the final shell CAD and leg PCB are locked. Sign up through the shop to hear first.
Kit $299 or assembled $369, pre-order. Parts are also sold one by one.